GULP3R: Gaussian Underwater spLatting with semantic Perception for 3D Reconstruction. Creating Labeled 3D Maps from Camera Images
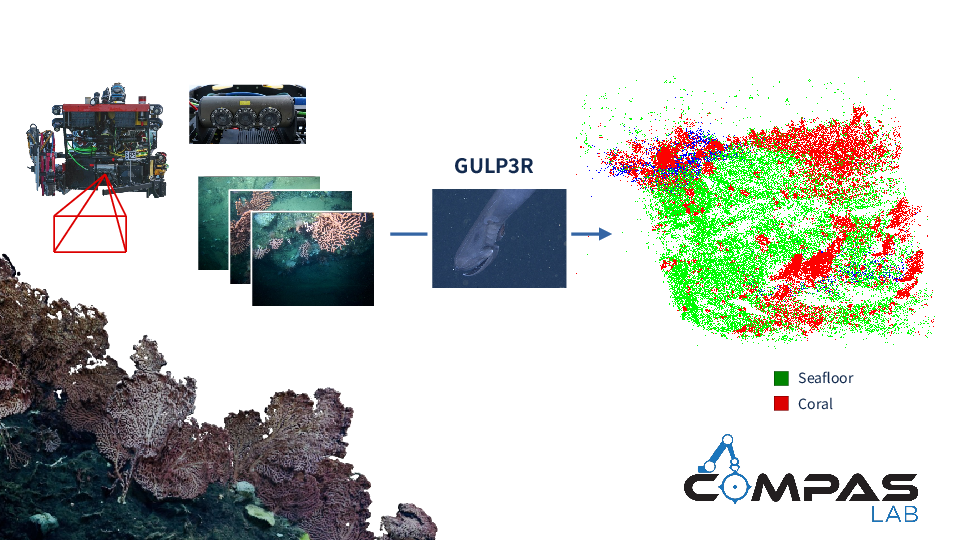 MBARI-CoMPAS Lab Summer Internship - Completed
3D Underwater Semantic Reconstruction Research Internship - 2026
Python - SfM - Gaussian Splatting - SAM3
This work addresses the reconstruction of semantic maps, which are labeled digital 3D reconstructions that allow scientists to study the geology and ecology of benthic environments more efficiently, as well as support unmanned underwater vehicles’ context-aware navigation.
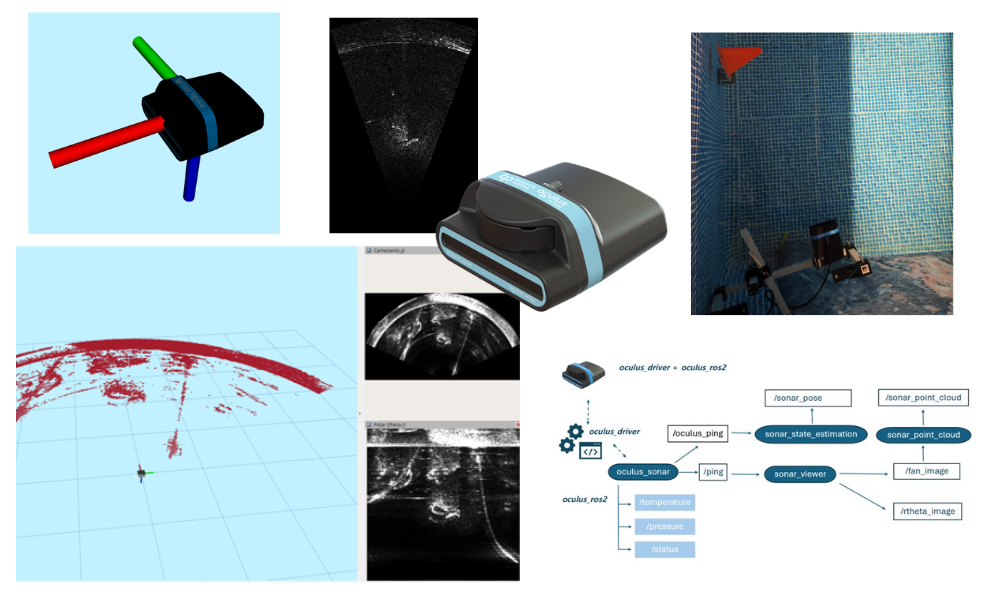 PhD Research Project - Ongoing
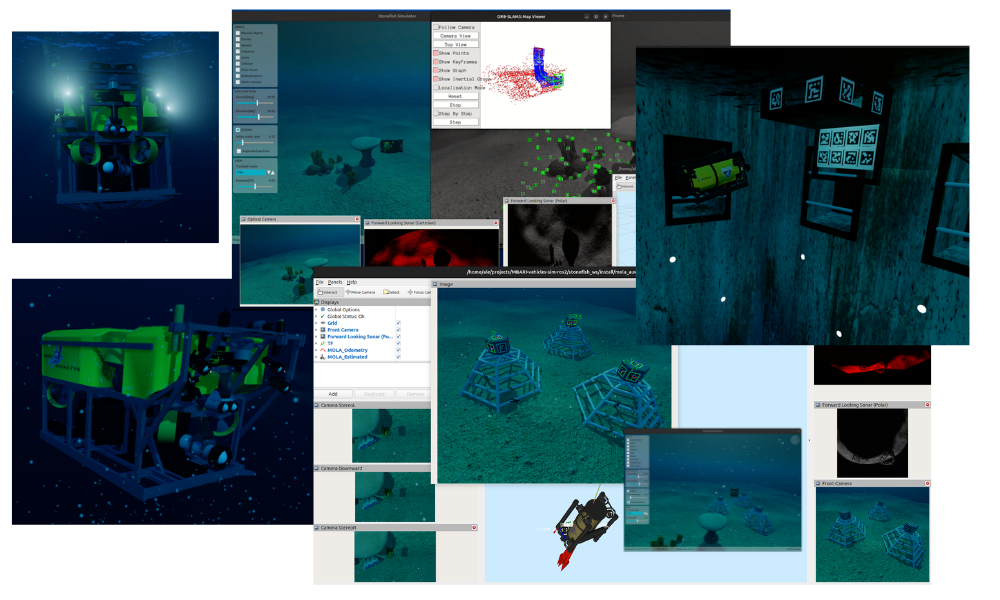 Personal Project - Ongonig
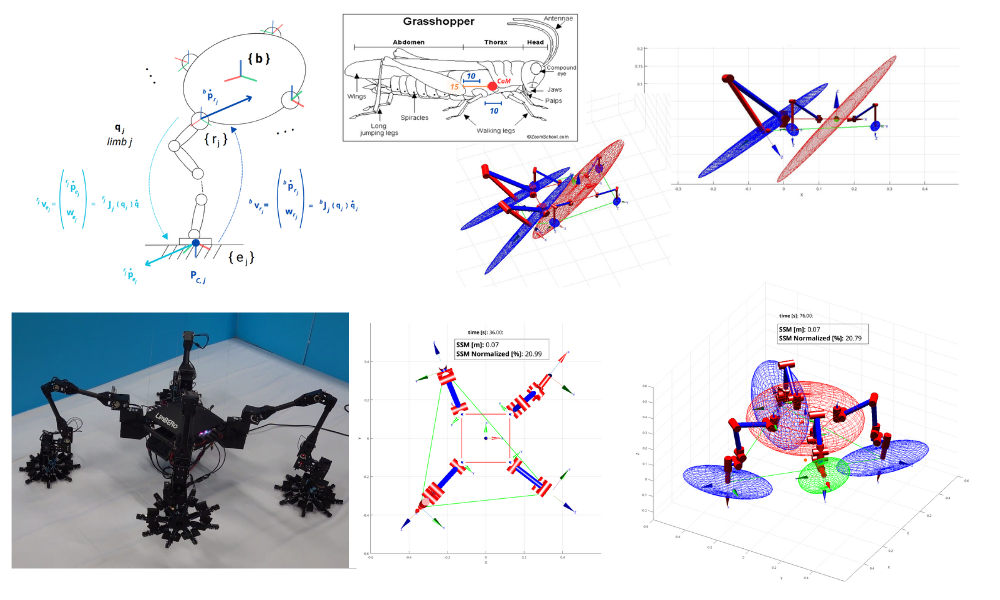 SRL Sequel - Completed
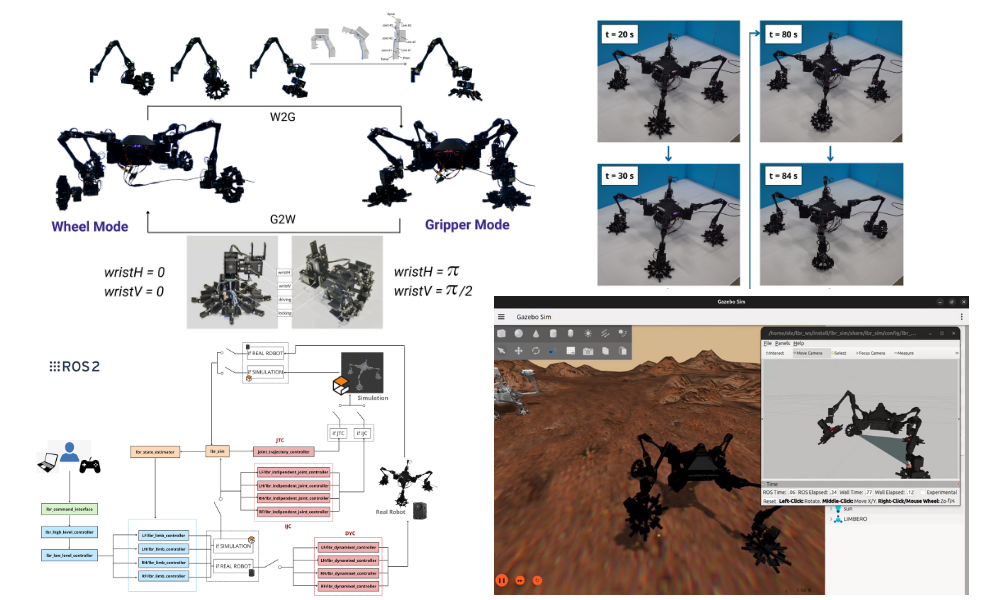 Research Project at SRL - Completed
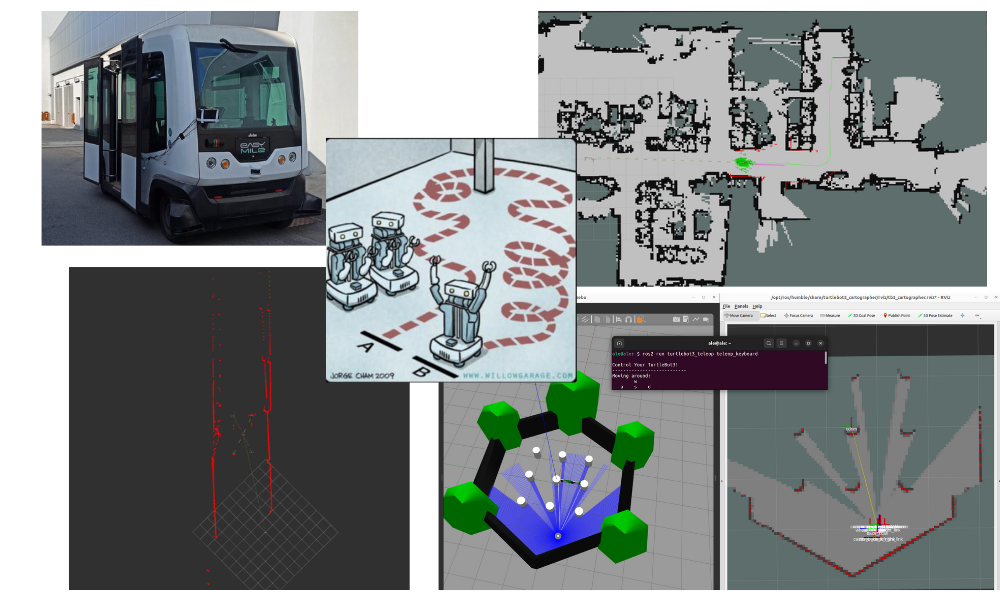 University Project + Extra Course -Completed
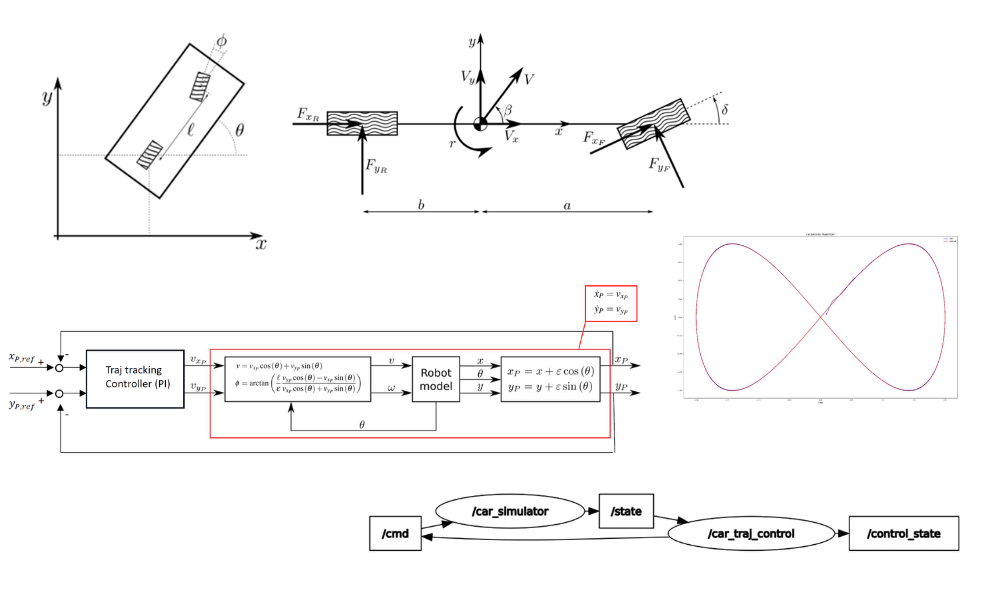 University Project-Completed
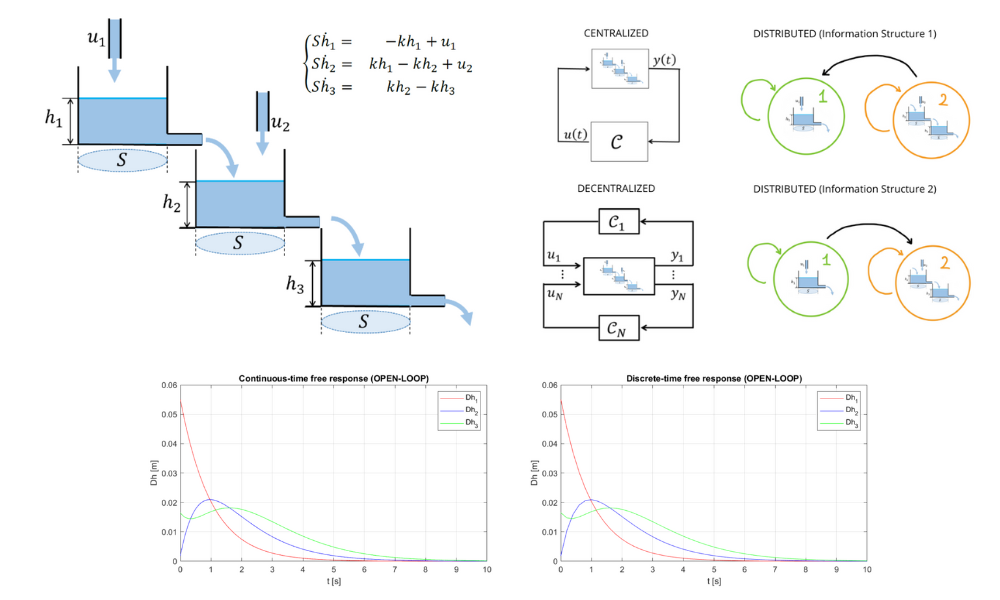 University Project-Completed
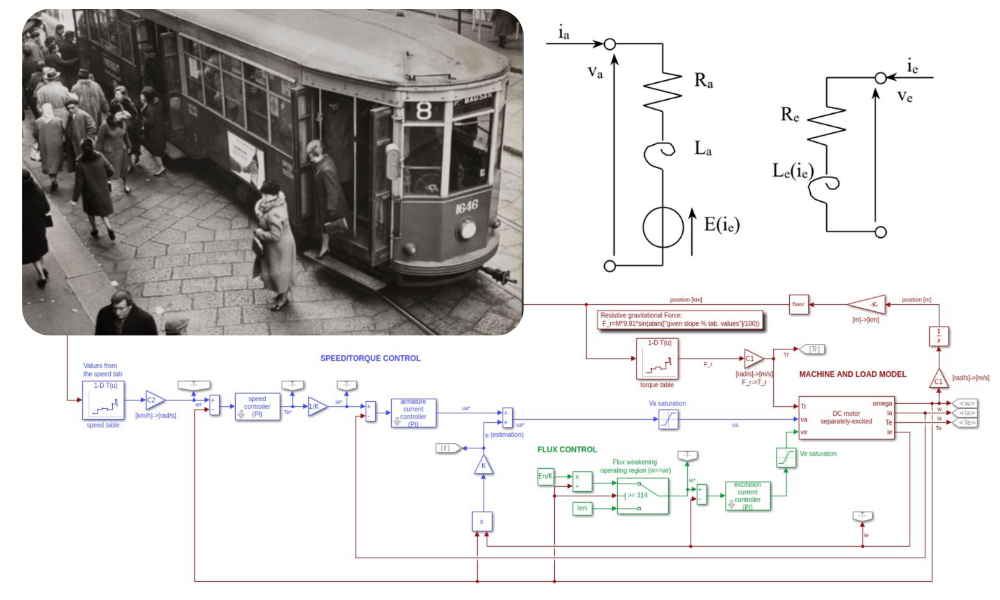 University Project-Completed
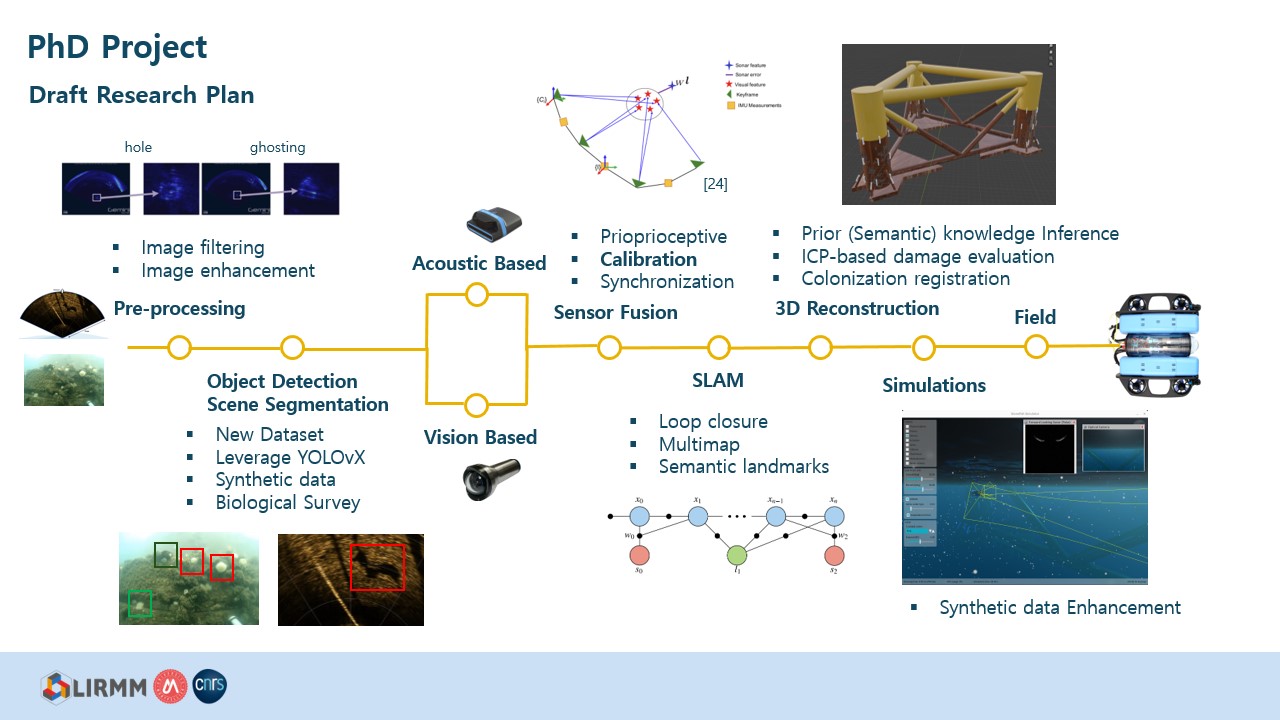 PhD Topic Presentation - 14/01/2026
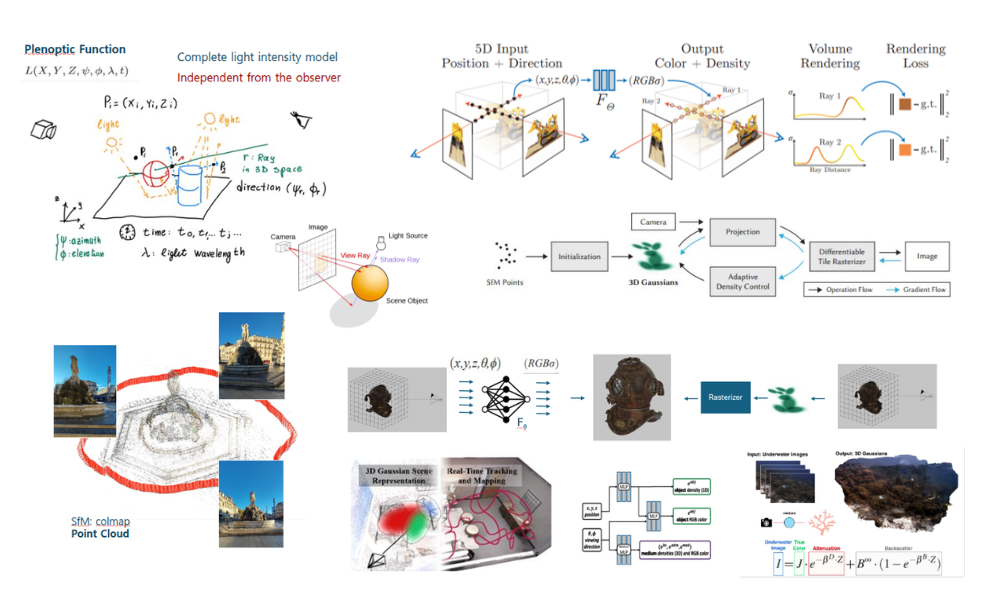 PhD Review - 20/01/2026